MJLab
EnvPool implements the twelve built-in training tasks from
MJLab 1.6.0
in C++. Each upstream ID has a versioned EnvPool ID and an alias without the suffix:
Mjlab-Cartpole-Balance-v0 and Mjlab-Cartpole-Balance, for example.
The physics and observation cameras use ahead-of-time CPU kernels from
MuJoCo-Warp 3.11.0 and Warp 1.14.0. This preserves the upstream float32
simulation path. Python MJLab, Torch, a GPU, and a runtime kernel compiler are
not required to use these environments. The ordinary MuJoCo renderer provides
the separate public render() images.
Models, textures, and serialized CPU graphs are installed by
envpool-assets-mjlab. They are shared between tasks without data loss and kept out
of the core EnvPool wheel. Motion recordings are user inputs and are not
bundled in that asset package.
Task Coverage
Observations are dictionaries with actor and critic entries, plus
camera for the three visual manipulation tasks. All entries and actions
use float32. Action spaces are unbounded, matching the upstream presets;
the native action manager applies each preset’s scaling and actuator limits.
Shapes below exclude the leading environment dimension.
Every ID in this table also accepts the -v0 suffix.
Task ID |
Action |
Actor |
Critic |
Camera |
Steps |
|---|---|---|---|---|---|
|
1 |
5 |
5 |
none |
1000 |
|
1 |
5 |
5 |
none |
1000 |
|
7 |
29 |
29 |
none |
1000 |
|
7 |
26 |
29 |
|
1000 |
|
7 |
26 |
29 |
|
1000 |
|
7 |
26 |
26 |
|
1000 |
|
29 |
160 |
286 |
none |
500 |
|
29 |
154 |
286 |
none |
500 |
|
29 |
99 |
111 |
none |
1000 |
|
12 |
48 |
72 |
none |
1000 |
|
29 |
286 |
298 |
none |
1000 |
|
12 |
235 |
259 |
none |
1000 |
The rough-terrain presets include flat ground, ascending and descending stairs, ascending and descending slopes, random rough ground, and waves. Terrain columns are distributed across the pool according to the upstream proportions; a pool with at least seven environments includes all columns. Training noise, domain randomization, command resampling, and curricula remain enabled. The upstream play configurations and external task plugins are not additional registered tasks in this family.
Rendered Examples
Each row compares EnvPool on the left with official MJLab on the right after identical deterministic actions. The image generator first verifies the complete episode and its rendered frames. Rough-terrain examples use the wave column; tracking examples use the generated test motion, without a trained policy.

Cartpole tasks.
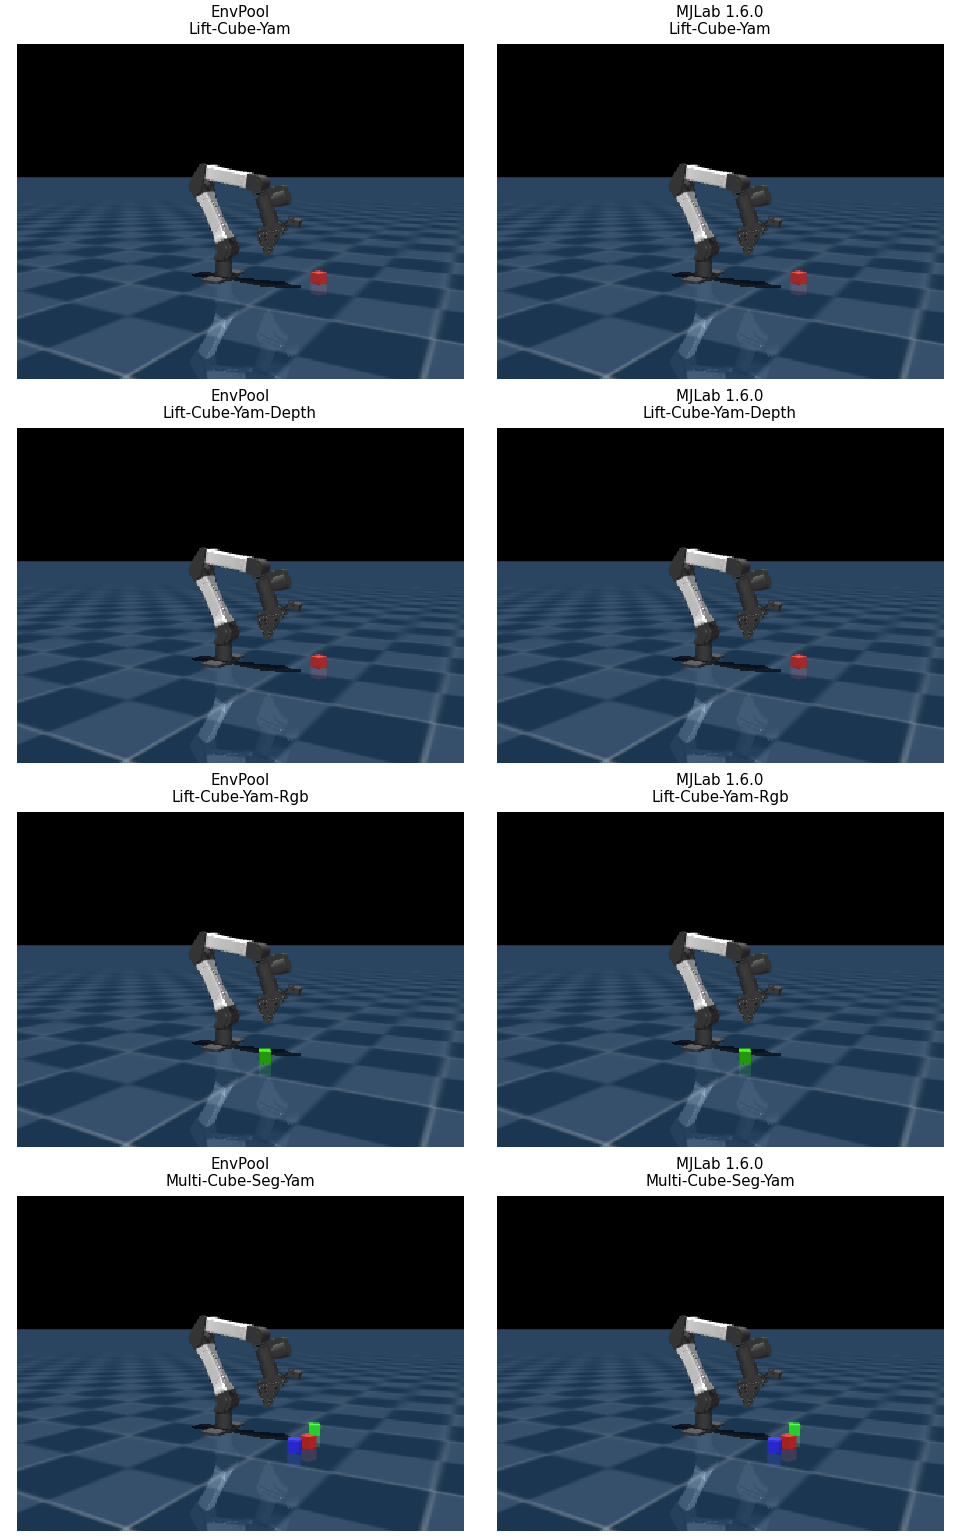
Yam manipulation tasks. These show the public scene renderer; observation cameras are separate and are checked by the alignment tests as well.
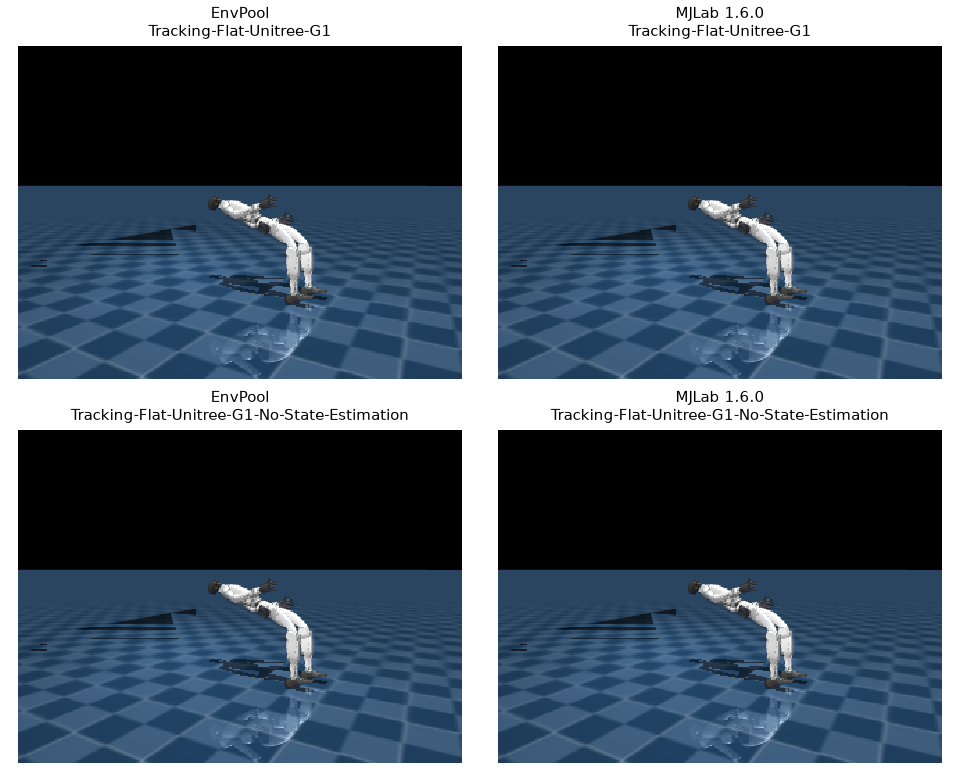
G1 motion tracking tasks.
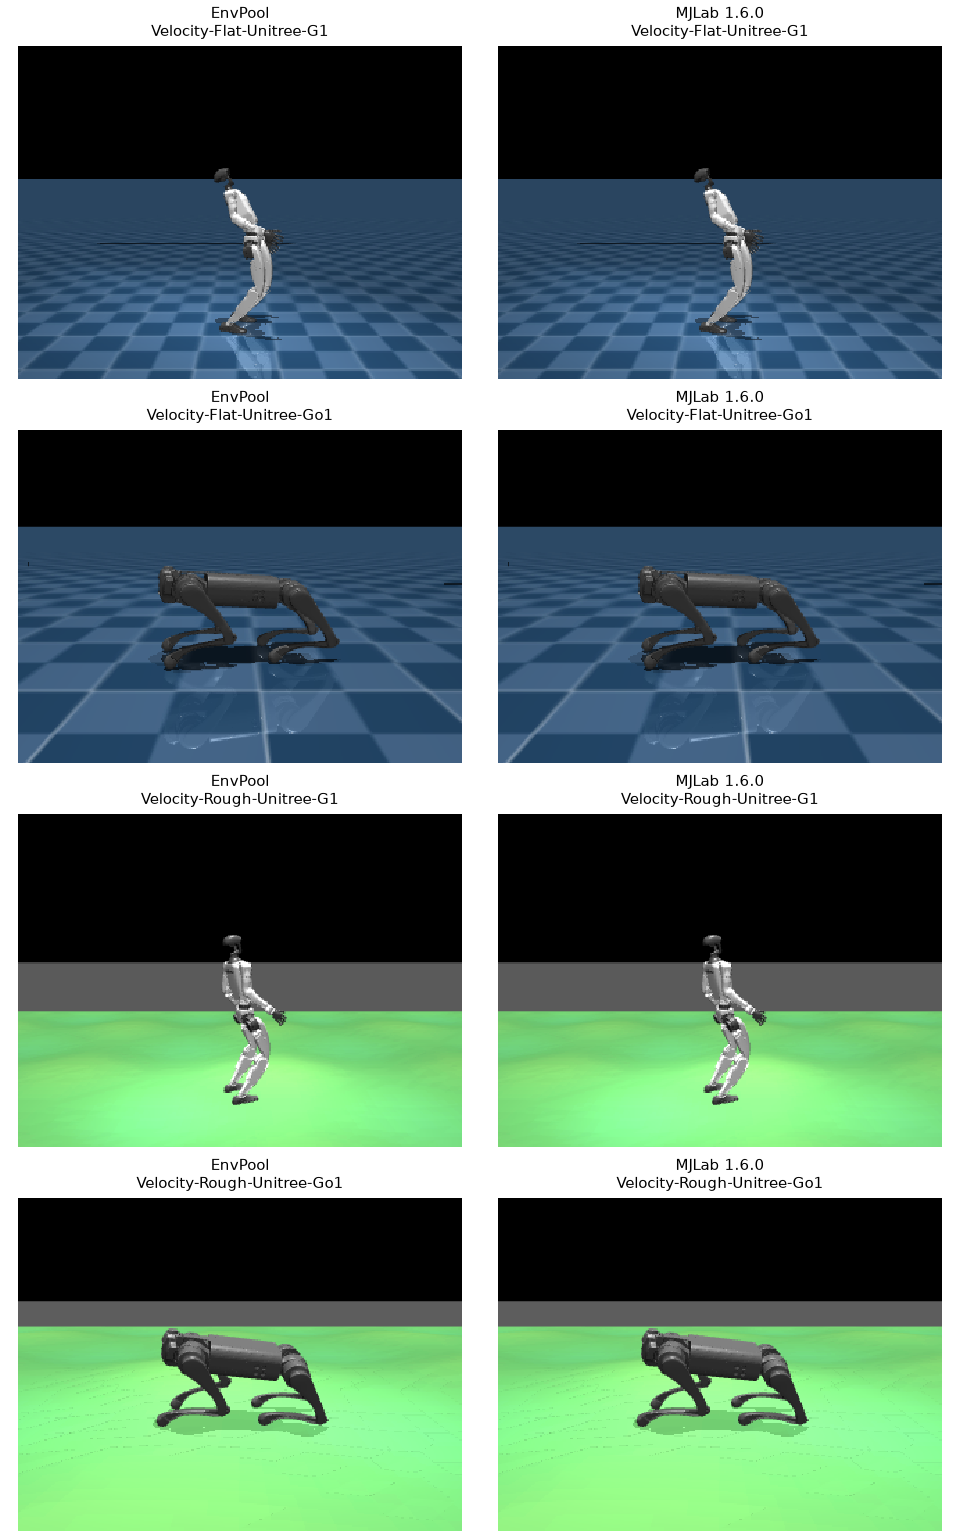
G1 and Go1 velocity tasks.
Usage
import envpool
import numpy as np

env = envpool.make_gymnasium(
    "Mjlab-Velocity-Flat-Unitree-Go1-v0",
    num_envs=4,
    num_threads=2,
    seed=42,
    render_mode="rgb_array",
    render_width=320,
    render_height=240,
)
try:
    obs, info = env.reset()
    action = np.zeros((4, *env.action_space.shape), dtype=np.float32)
    obs, reward, terminated, truncated, info = env.step(action)
    frames = env.render(env_ids=[0, 2])  # uint8, (2, 240, 320, 3)
finally:
    env.close()
make_dm exposes the same dictionary through timestep.observation.obs.
An episode termination sets the discount to zero; a time-limit truncation
keeps it at one. As in other EnvPool families, stepping a completed slot resets
it before the next episode. max_episode_steps may shorten the preset’s
episode limit. info contains EnvPool slot identifiers and elapsed_step;
MJLab’s training logger and Weights & Biases integration are not part of this API.
Each slot has its own RNG and episode state. Curriculum steps and motion failure statistics are maintained per slot, so asynchronous scheduling does not couple one slot’s reset distribution to another slot’s progress. This corresponds to independent upstream single-environment instances, rather than the shared adaptive histogram in one upstream training batch. Terrain-column allocation still uses the pool size as described above.
Motion Tracking Input
Both tracking tasks require motion_file="/path/to/motion.npz". Upstream
does not supply a default recording, and EnvPool does not download one or
contact a motion registry. Use the pinned MJLab motion format, with these
arrays in the robot’s joint and body ordering:
Array |
Shape |
Meaning |
|---|---|---|
|
|
G1 joint positions and velocities |
|
|
Body positions in world coordinates |
|
|
Body orientations in |
|
|
Body linear and angular velocities in world coordinates |
Use 50 Hz samples: the reference advances one frame per 0.02-second control
step, as in the pinned upstream task. All six arrays must have the same
positive frame count and finite numeric values. Stored and deflated NPZ files,
NumPy C and Fortran array orders, both byte orders, and float16/32/64 values are
accepted and converted to float32. Object arrays are rejected. The native
reader checks archive sizes, array shapes, and data integrity before simulation.
The test fixture is generated locally using the pinned upstream CSV conversion code. It exercises moving references and short-recording wraparound, but is not a motion dataset or a default training benchmark.
Building from source
The official SDK is needed only to generate C++ sources and model data, not to
run EnvPool. Its ARM Linux wheel requires glibc 2.34 or newer. The ARM release
job therefore generates portable inputs in an Ubuntu container, then compiles
them inside manylinux 2.28. Other platforms generate them during the ordinary
build. This keeps the existing wheel compatibility floor.
For a source build on an older Linux system, prepare the usual build dependencies on a supported host, then run:
make bazel-pip-requirement-dev
bazel build --config=test //third_party/mjlab:codegen_bundle
Copy bazel-bin/third_party/mjlab/codegen/codegen_input.tar.gz into
third_party/mjlab/ in the same source revision. Bazel validates the generator
recipe and every archived file before using it. Remove that input to regenerate
locally. Neither the archive nor the SDK is included in a released wheel.
Validation
The CPU oracle uses unmodified MJLab 1.6.0, Torch 2.9.0, MuJoCo-Warp 3.11.0, and
Warp 1.14.0. It synchronizes native state once immediately after reset, then
compares complete episodes driven by identical external actions. Tests cover
every task, observations including camera pixels, rewards, termination,
truncation, physics state, and public rendering at multiple steps.
The oracle uses the upstream auto_reset=False option to retain terminal
observations; EnvPool resets a completed slot on its next step.
Reward reductions use standard C++ math; the terrain-plane fit uses MuJoCo’s
3-by-3 eigenvalue solver. Only arithmetic and trigonometry that set physical state
retain the pinned oracle’s rounding, since tiny changes there can grow into
different contact trajectories. Sine and cosine use statically linked MKL on
x64 and SLEEF on ARM64; no additional math runtime or LAPACK solver is needed.
Oracle comparisons allow float32 rounding differences (relative tolerance
1e-5, absolute tolerance 1e-6), while discrete outputs and native
same-seed replays remain exact. The tests still compare every step through
termination; they do not substitute final scores for behavioral alignment.
RGB rendering shares the existing MuJoCo bootstrap. On macOS, identical scenes
can produce sparse CGL/Metal color differences. The shared image check allows
at most five intensity levels in any color channel and a mean absolute error
of 0.01 per frame, on the 0-to-255 scale. Mjlab-Cartpole-Balance and
Mjlab-Cartpole-Swingup use bounds of 32 and 0.025: the official MuJoCo renderer alone reproduces a
shadow difference of 25 levels over 13 pixels when replaying the same scene
with different draw histories. Physics and other task budgets remain unchanged;
other platforms retain exact RGB comparisons.
Independent tests observe native resets without oracle synchronization. They check different seeds, consecutive resets, parallel slots, and replay of the whole reset sequence. Independently randomized goals, poses, model properties, and terrain are checked separately so observation noise cannot conceal a frozen task component. This preserves the regression boundary from issue 432.